Validation
These commands launch Isaac Sim unless they only check an existing report. Complete installation first.
In the activated setup environment:
python -m pip install scipy rtree
MPLBACKEND=Agg python scripts/dex01_on_tesollo_dg5f.py \
  --headless \
  --flat-indenter \
  --max-steps 1200 \
  --verify-thumb \
  --verification-report /tmp/dex01-hand.json
python scripts/verify_dex01_sim.py --check-hand-report /tmp/dex01-hand.json
The 0.1 kg flat load should settle near 0.981 N on each pressed finger, with zero on unloaded fingers. The checker verifies forces, counter-object filtering and momentum balance, then reports the separate thumb probe result. The gear can rock and is not a calibration load.
For the complete 738-contact sweep:
python scripts/verify_dex01_sim.py \
  --headless \
  --sweep-all \
  --transformed-probe \
  --num-envs 2 \
  --report /tmp/dex01-contact.json
For articulated motion checks, see stationary pressing.
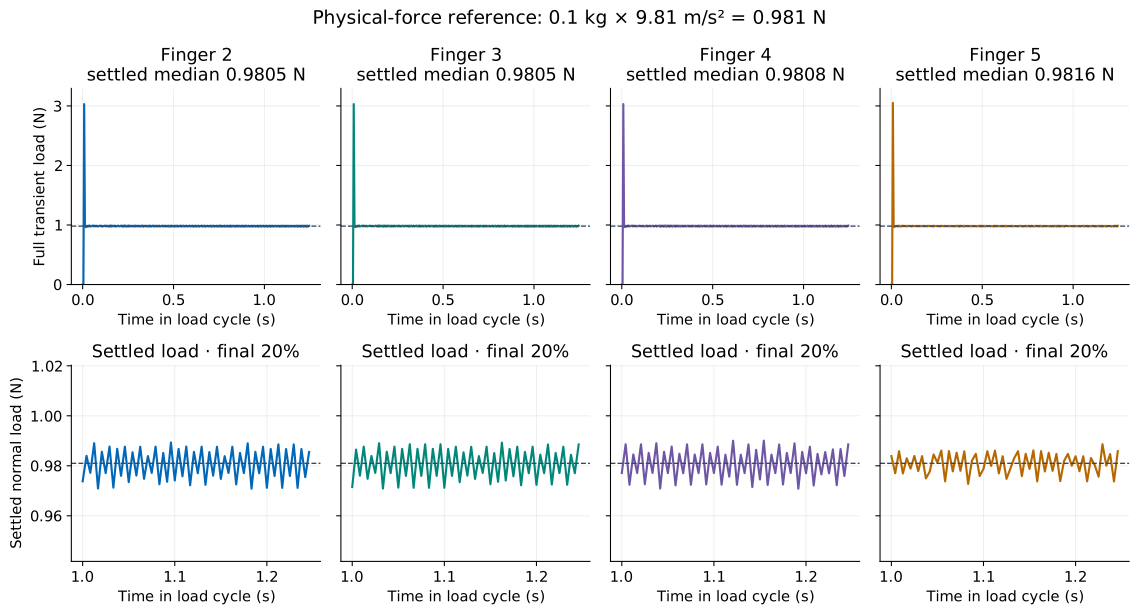
The full load cycles include the initial impact transient. The lower panels
show the final 20% used for settling checks. The dashed line is m × g.
Verified fixture results
On October 12, 2026, the unchanged runtime at commit
3818a8388c970ced7ad03539668d26c1a68e0add was checked on Linux with
Isaac Sim 5.1.0 and NVIDIA RTX 4500 Ada hardware:
Check |
Result |
|---|---|
Repository geometry, mapping, force, and visualization tests |
98 passed |
Flat-load report checker, fingers 2–5 |
0.980522, 0.980521, 0.980793, 0.981630 N; unloaded fingers zero |
Thumb localization and counter-object filtering |
Passed |
All 738 taxels, transformed probes, two environments |
Passed |
Fixed-wrist articulated press and release checker |
Passed; reported sustained load 3.916 N |
The hand report checker also checks filtered PhysX force agreement and momentum balance. These results establish the tested physical-force fixtures and trajectories. Check new articulated poses for clearance as part of task validation. The articulated run emitted a warning that the gear’s inherited articulation root was ignored on its kinematic body; its invariant and contact checks passed.
Inspect the assembled geometry
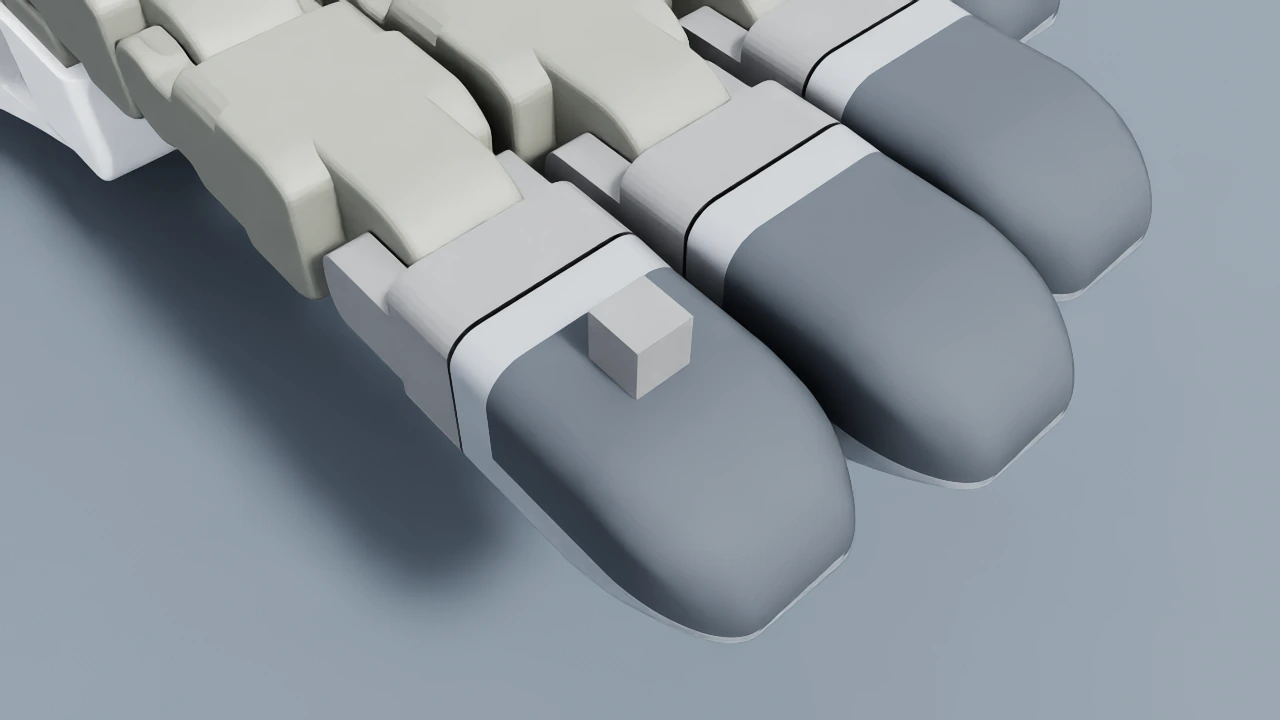
The captured flat-load fixture retains the verified live body poses. Native RTX rendering preserves those poses and the recorded tactile frames.
On a host with the validated display/camera driver, generate several views:
MPLBACKEND=Agg python scripts/dex01_on_tesollo_dg5f.py \
  --headless \
  --enable_cameras \
  --max-steps 1 \
  --inspection-dir /tmp/dex01-views
Inspect the output images for five fully mounted fingertips, clearance around the rigid finger backing, and alignment of the contact sample markers with the exterior. For any new trajectory, check contact and release as well as the visual fit. A screenshot complements the numerical checks; it does not replace a force or invariance report.
Re-run the commands above when geometry or sensing changes. Keep the JSON reports and simulator logs with review evidence. Documentation build checks validate the site, while these commands validate the simulation.