RTD Temperature Measurement Demo
The ADuCM360_demo_cn0337 is a RTD temperature measurement demo project for the EVAL-ADICUP360 base board with additional EVAL-CN0337-PMDZ pmod, created using the GNU ARM Eclipse Plug-ins in Eclipse environment.
General description
This project is a good example for how to use EVAL-ADICUP360 board in different combinations with pmod boards. It expand the list of possible applications that can be done with the base board.
The ADuCM360_demo_cn0337 project uses the EVAL-CN0337-PMDZ pmod which is a completely isolated 12-bits, 300 kSPS RTD temperature measuring system (with only three active devices) that processes the output of a Pt100 RTD and includes an innovative circuit for lead-wire compensation using a standard 3-wire connection.
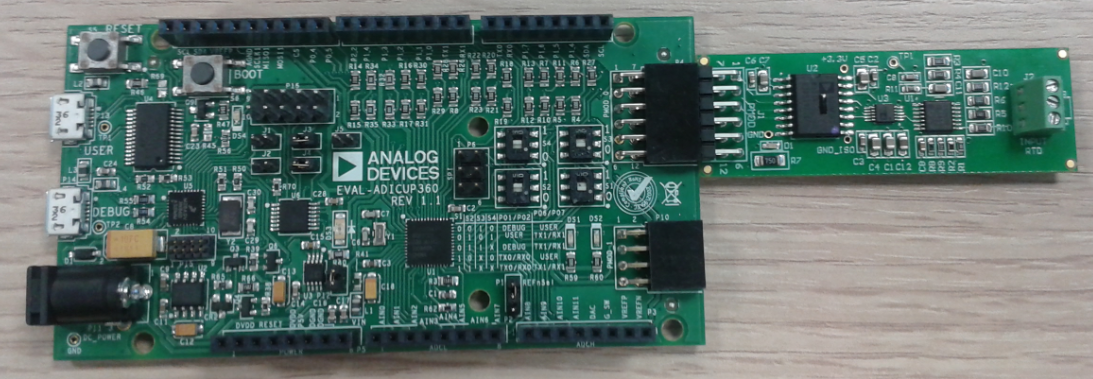
The CN0337 circuit translates the RTD input resistance range (100 Ω - 212.05 Ω for a 0°C - 300°C temperature) into voltage levels compatible with the input range of the ADC (0 V - 2.5 V). The 12-bits ADC value is received via SPI interface of the EVAL-ADICUP360 board.
The EVAL-CN0337-PMDZ comes with an evaluation software which can help you to test and to calibrate your pmod before you use it with an RTD sensor.
Note
Please visit CN0337 Software User Guide page to find out how to get and how to use the CN0337 evaluation software.
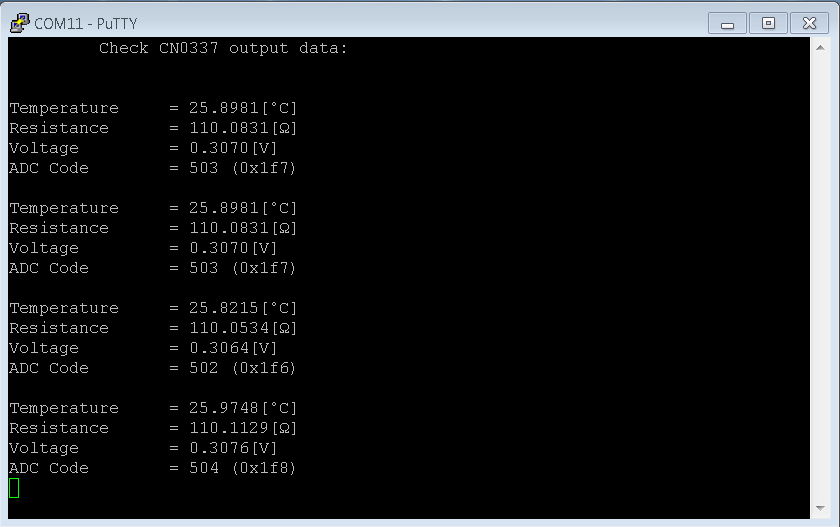
The ADuCM360_demo_cn0337 application processes ADC output value and make all necessary conversions in order to provide RTD measure results. A UART interface (9600 baud rate and 8-bits data length) is used to send the results to terminal window: RTD temperature and resistance values, voltage calculation and ADC code. If the resistance and temperature values are out of range you get an error message which means that you need to check your settings.
The output values are displayed when you press ENTER key (CR) from the keyboard. Also you can decide how often the measurements take place (see SCAN_TIME parameter).
The project offers two method to calculate the RTD resistance, giving you the possibility to get more accurate RTD measurement results (see CN0337 circuit note).
You can use transfer function of the circuit which calculate RTD resistance based on voltage changed value and circuit gain:
Rrtd = (Vout - Voffset)/Gain
Or you can use the two-point calibration method which used the ADC output values for 2 different measurements: first using Rmin = 100 Ω (ADC1) precision resistor and second with Rmax = 212.05 Ω (ADC2) resistor.
Rrtd = Rmin + [(Rmax - Rmin)/(ADC2 - ADC1)]*(ADCrtd - ADC1)
Because the transfer function of the RTD (resistance vs. temperature) is nonlinear is needed a software linearization to eliminate the nonlinearity error of the RTD Pt100 sensor. This project used so called Piecewise Linear Approximation method.
Piecewise Linear Approximation Method
This method characterized by taking linear approximation one step further, one can conceptualize any number of linear segments strung together to better approximate the nonlinear RTD transfer function. Generating this series of linear segments so that each segment’s endpoints meet those of neighboring segments results in what can be viewed as a number of points connected by straight lines.
These coefficients is calculated once to best match the RTD’s nonlinear transfer function and then stored permanently in a look-up table (see C_rtd[] table). From this table of coefficients, the software can perform simple linear interpolation to determine temperature based on measured RTD resistance.
The look-up table can have how many coefficients you needed depending how accurate you want to be. For this project the RTD resistance range is separated into 100 linearization segments.
Note
This method is also used in the AN-709 application note which provide also an RTD coefficient generator tool that you also can use.
Demo Requirements
The following is a list of items needed in order to replicate this demo.
Hardware
EVAL-ADICUP360
EVAL-CN0337-PMDZ
3-Wire PT100 RTD
Mirco USB to USB cable
PC or Laptop with a USB port
Software
ADuCM360_demo_cn0337 software
CrossCore Embedded Studio (2.7.0 or higher)
ADuCM36x DFP (1.0.2 or higher)
CMSIS ARM Pack (4.3.0 or higher)
Serial Terminal Program
Such as Putty or Tera Term
Setting up the hardware
To program the base board, set the jumpers/switches as shown in the next figure. The important jumpers/switches are highlighted in red.
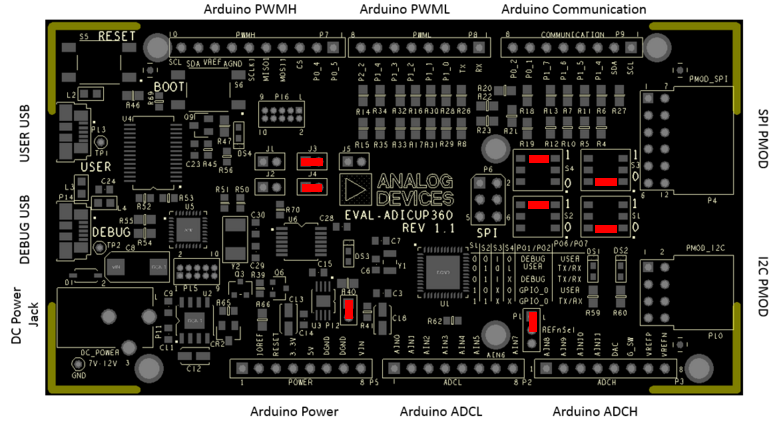
Plug the EVAL-CN0337-PMDZ PMOD in the EVAL-ADICUP360 base board, via the PMOD_SPI port (P4).
Plug in the USB cable from the PC to the EVAL-ADICUP360 base board via the Debug USB.(P14)
Obtaining the Source Code
There are two basic ways to program the ADICUP360 with the software for the CN0337.
Dragging and Dropping the .Bin to the MBED drive
Building, Compiling, and Debugging using CCES
Using the drag and drop method, the software is going to be a version that Analog Devices creates for testing and evaluation purposes. This is the EASIEST way to get started with the reference design.
Importing the project into CrossCore is going to allow you to change parameters and customize the software to fit your needs, but will be a bit more advanced and will require you to download the CrossCore toolchain.
The software for the ADuCM360_demo_cn0337 demo can be found here:
Download
Prebuilt CN0337 Bin File
Complete CN0337 Source Files
Note
For more information on importing, debugging, or other tools related questions, please see the tools user guide.
Configuring the Software Parameters
Converter operation mode - AD7091R_OPERATION_MODE - POWER_DOWN to select power-down AD7091R mode of operation or NORMAL for normal mode (AD7091R.h).
#define AD7091R_OPERATION_MODE POWER_DOWN
Converter scan time - SCAN_TIME - how often (msec) to read conversion results (AD7091R.h).
#define SCAN_TIME 500
Converter reference voltage - VREF - reference voltage (V) for AD7091R converter (AD7091R.h).
#define VREF 2.5
RTD resistance calculation method - RTD_FORMULA - this parameter can be set as TRANSFER_FUNCTION or TWO_POINT_CALIBRATION (CN0337.h).
#define RTD_FORMULA TRANSFER_FUNCTION
RTD parameters - all needed parameters for RTD calculations (CN0337.h).
#define  TMIN         (0)            /* Tmin [˚C] */
#define  TMAX         (300)          /* Tmax [˚C] */
#define  RMIN         (100)          /* Resistance [Ohms] at Tmin */
#define  RMAX         (212.052)      /* Resistance [Ohms] at Tmax  */
#define  NSEG         100            /* Nr. of sections in look-up table */
#define  RSEG         1.12052        /* Resistance of each segment */
#define  ADC_MIN      152            /* ADC min for RMIN */
#define  ADC_MAX      4095           /* ADC max for RMAX */
Outputting Data
Serial Terminal Output
In order to view the data, you must flash the program to the EVAL-ADICUP360.
Once complete you will need to switch the USB cable from the DEBUG USB (P14) to the USER USB (P13).
Then follow the UART settings below with the serial terminal program.
Following is the UART configuration.
Select COM Port
Baud rate: 9600
Data: 8 bit
Parity: none
Stop: 1 bit
Flow Control: none
The user must press the <ENTER> key every time they want new data.
How to use the Tools
The official tool we promote for use with the EVAL-ADICUP360 is CrossCore Embedded Studio. For more information on downloading the tools and a quick start guide on how to use the tool basics, please check out the Tools Overview page.
Importing
For more detailed instructions on importing this application/demo example into the CrossCore Embedded Studios tools, please view our How to import existing projects into your workspace section.
Debugging
For more detailed instructions on importing this application/demo example into the CrossCore Embedded Studios tools, please view our How to configure the debug session section.
Project structure
The ADuCM360_demo_cn0337 project use ADuCM36x C/C++ Project structure.
This project contains: system initialization part - disabling watchdog, setting system clock, enabling clock for peripherals; port configuration for SPI0, UART via P0.1/P0.2; SPI, UART read/write functions; AD7091R control and RTD conversions.
In the src and include folders you will find the source and header files related to CN0337 software application. The Communication.c/h files contain SPI and UART specific data, meanwhile the AD7091R.c/h files contain the ADC control data and the CN0337.c/h files contain the RTD measurements management.
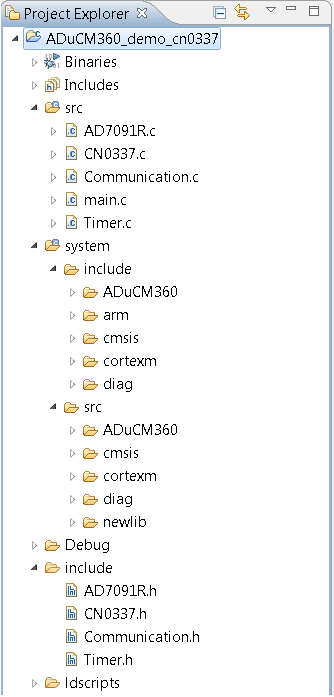
The RTE folder contains device and system related files:
Device Folder – contains low levels drivers for ADuCM360 microcontroller.(try not to edit these files)
system.rteconfig - Allows the user to select the peripherial components they need, along with the startup and ARM cmsis files needed for the project.